As published · arm held level
29.1°Sag below level while holding its rated payload. A slipped decimal put the forearm's centre of mass 2 m out.
 OmniLink
Start free ↗
OmniLink Services
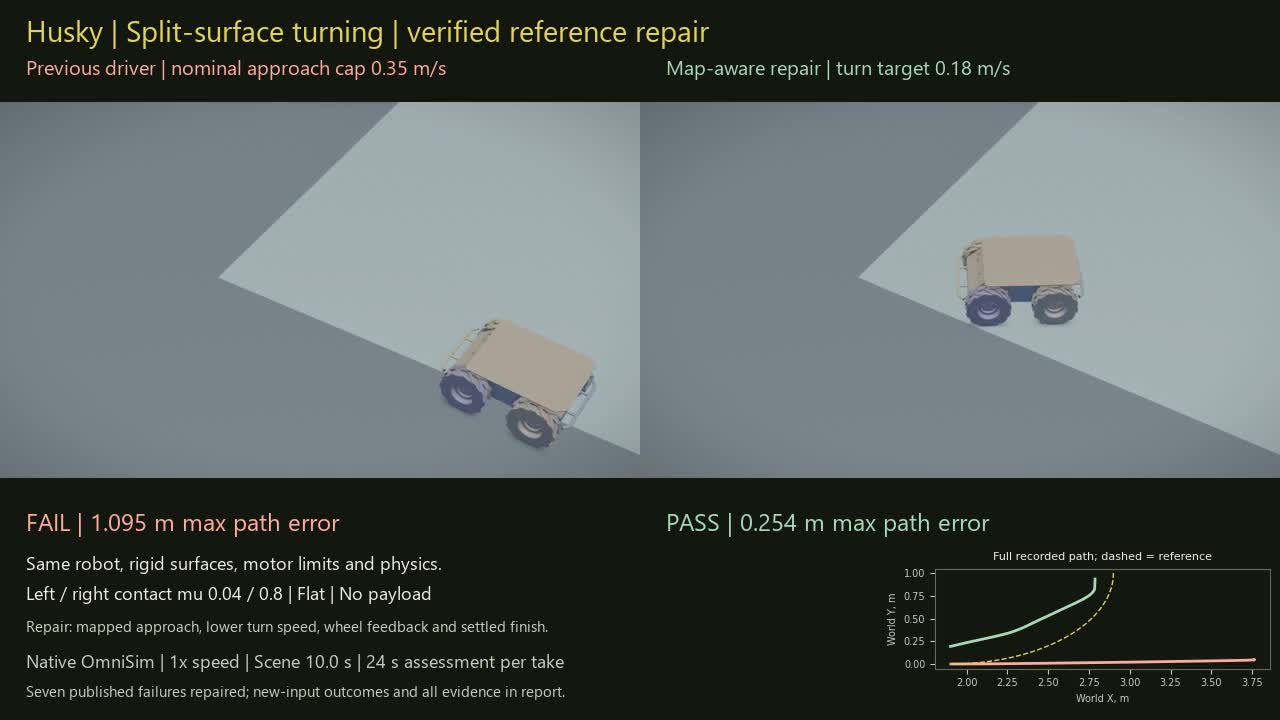
Focused engineering services, delivered with the report, source and tests you can run again. Assess braking, mixed-surface mobility, gait transitions or standing in OmniSim.
Service 01 · Husky · Jackal · Go2 · G1
We assess a defined behavior, evaluate bounded settings where the task includes tuning, and deliver the report, evidence and Windows tests your team can run again.
One supported model and reference controller. Applicable tax separate. Custom integration scoped separately.
Service 02 · Any URDF or CAD
We repair the robot description you publish, or build one from your CAD: masses, inertias, limits and joints checked against your datasheet, in OmniSim and in plain MuJoCo.
Fix of an existing description. Builds from CAD are quoted per robot. Applicable tax separate.
As published · arm held level
29.1°Sag below level while holding its rated payload. A slipped decimal put the forearm's centre of mass 2 m out.
After the maker's fix
1.28°The same hold on the corrected file, 7 days after our report.
Husky and Jackal braking, Go2 gait transitions and G1 standing have defined assessment packages. Five additional wheel profiles have adapters and still need qualification. Other robots, tasks and production controllers require separate scope. Tell us your model and the behavior you want to measure.
Discuss another robot ↗